Home
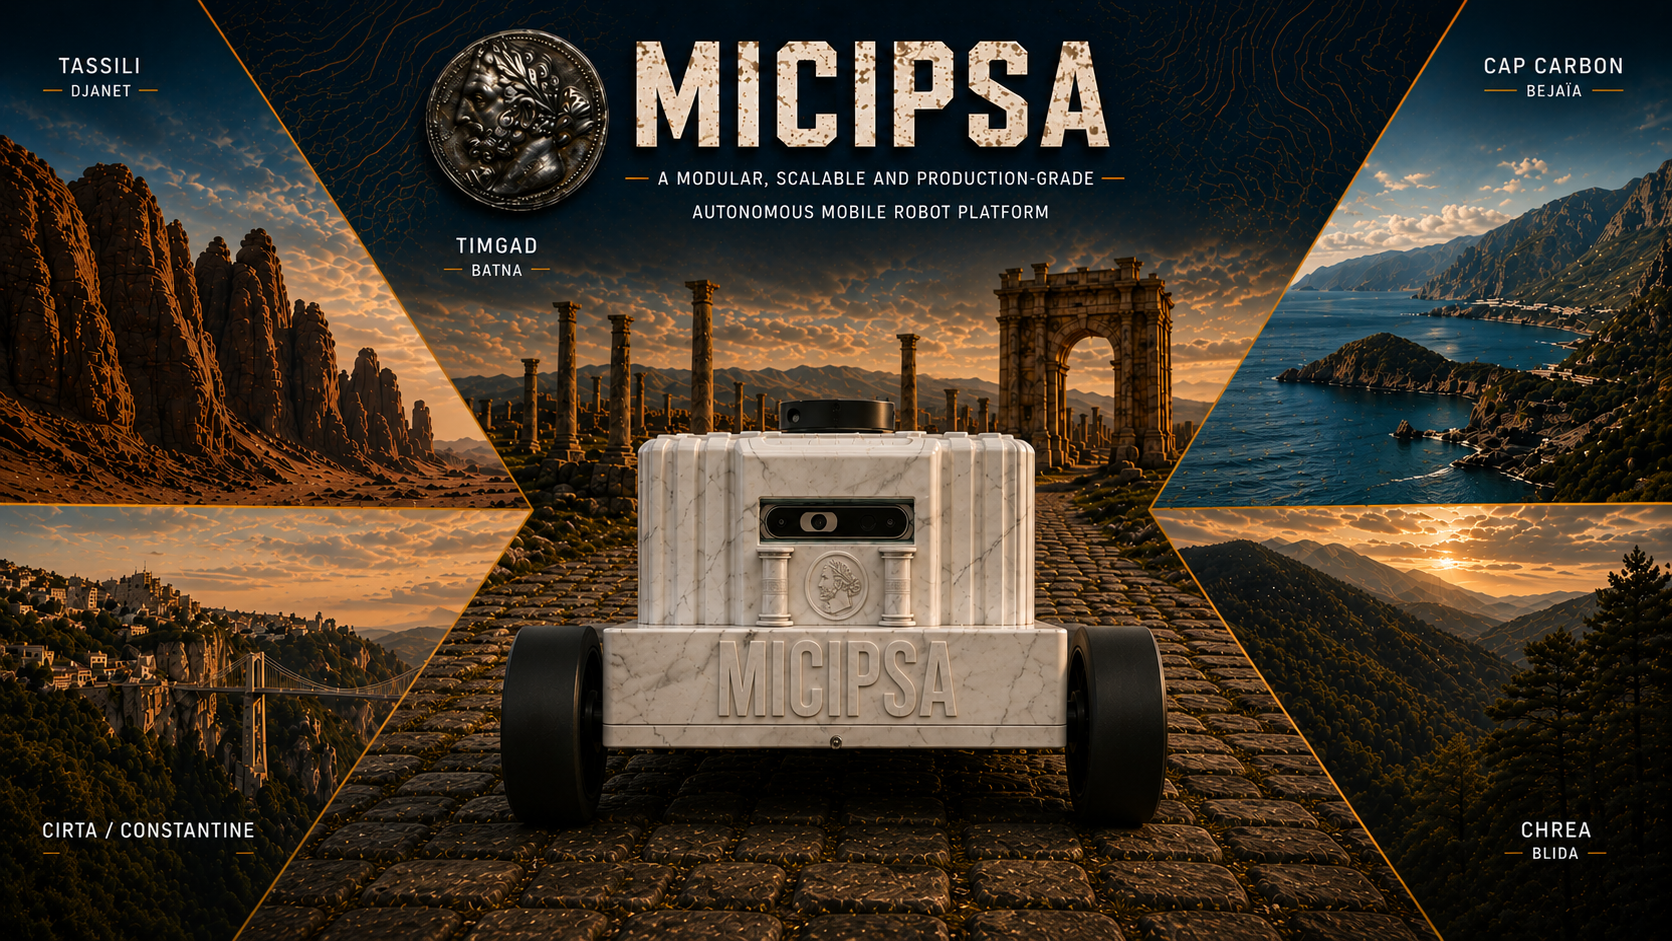
About The Project#
MICIPSA is a production-grade autonomous mobile robot (AMR) prototype, designed from the ground up as a clean, scalable, and reusable foundation for robotics development.
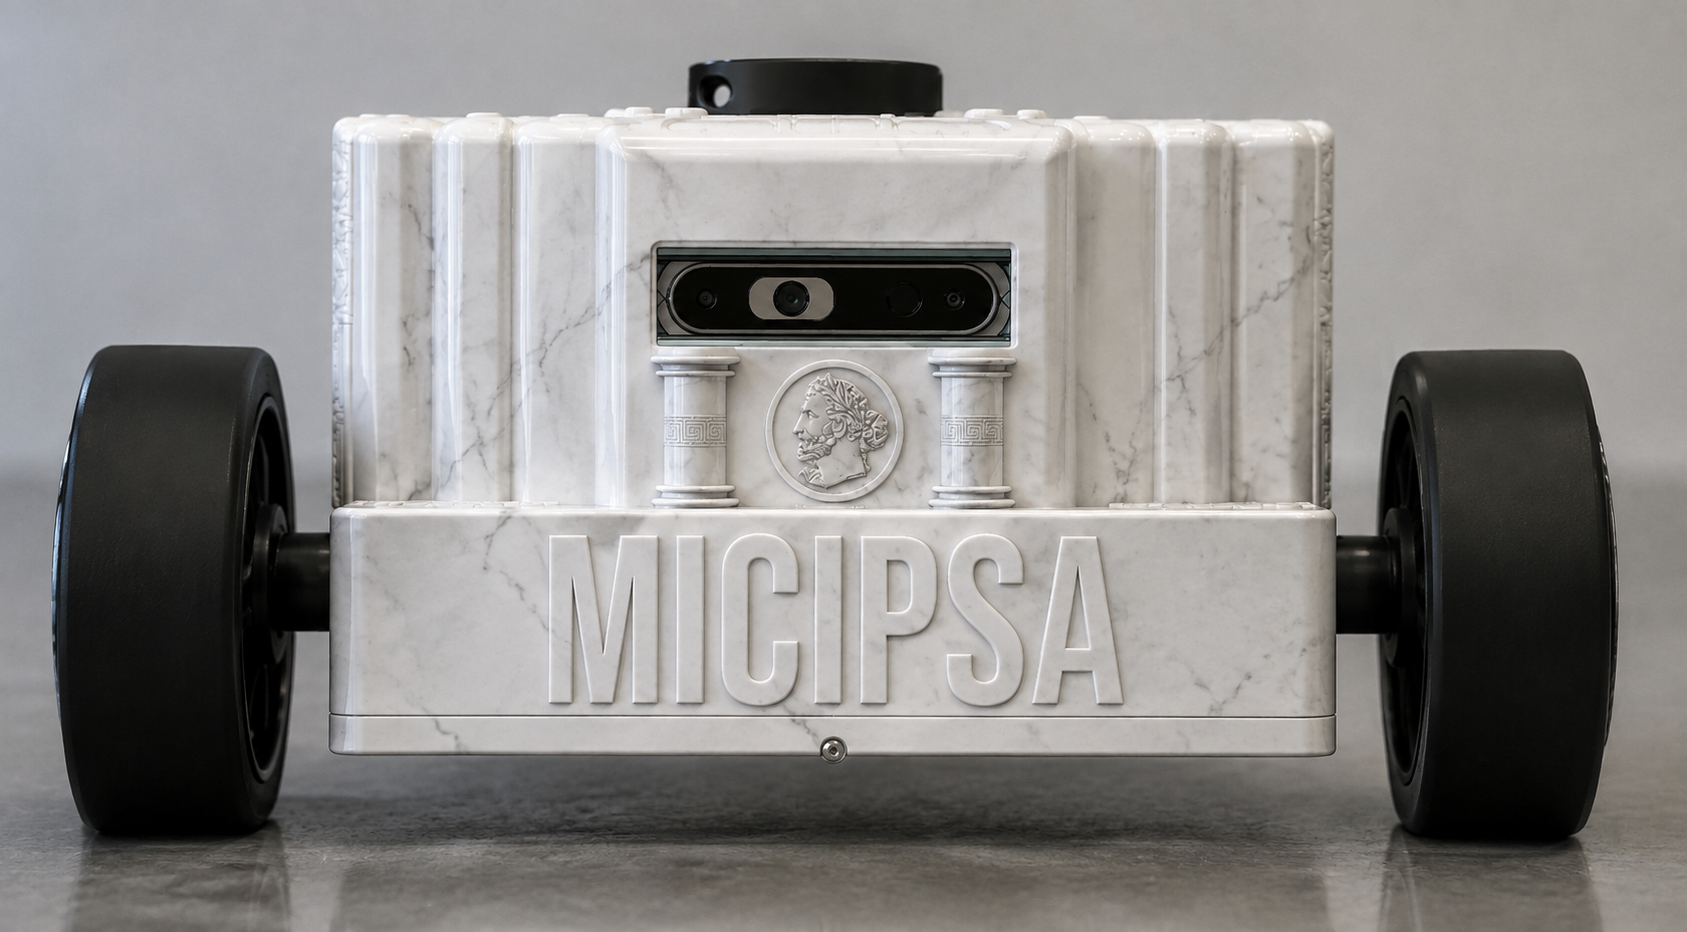
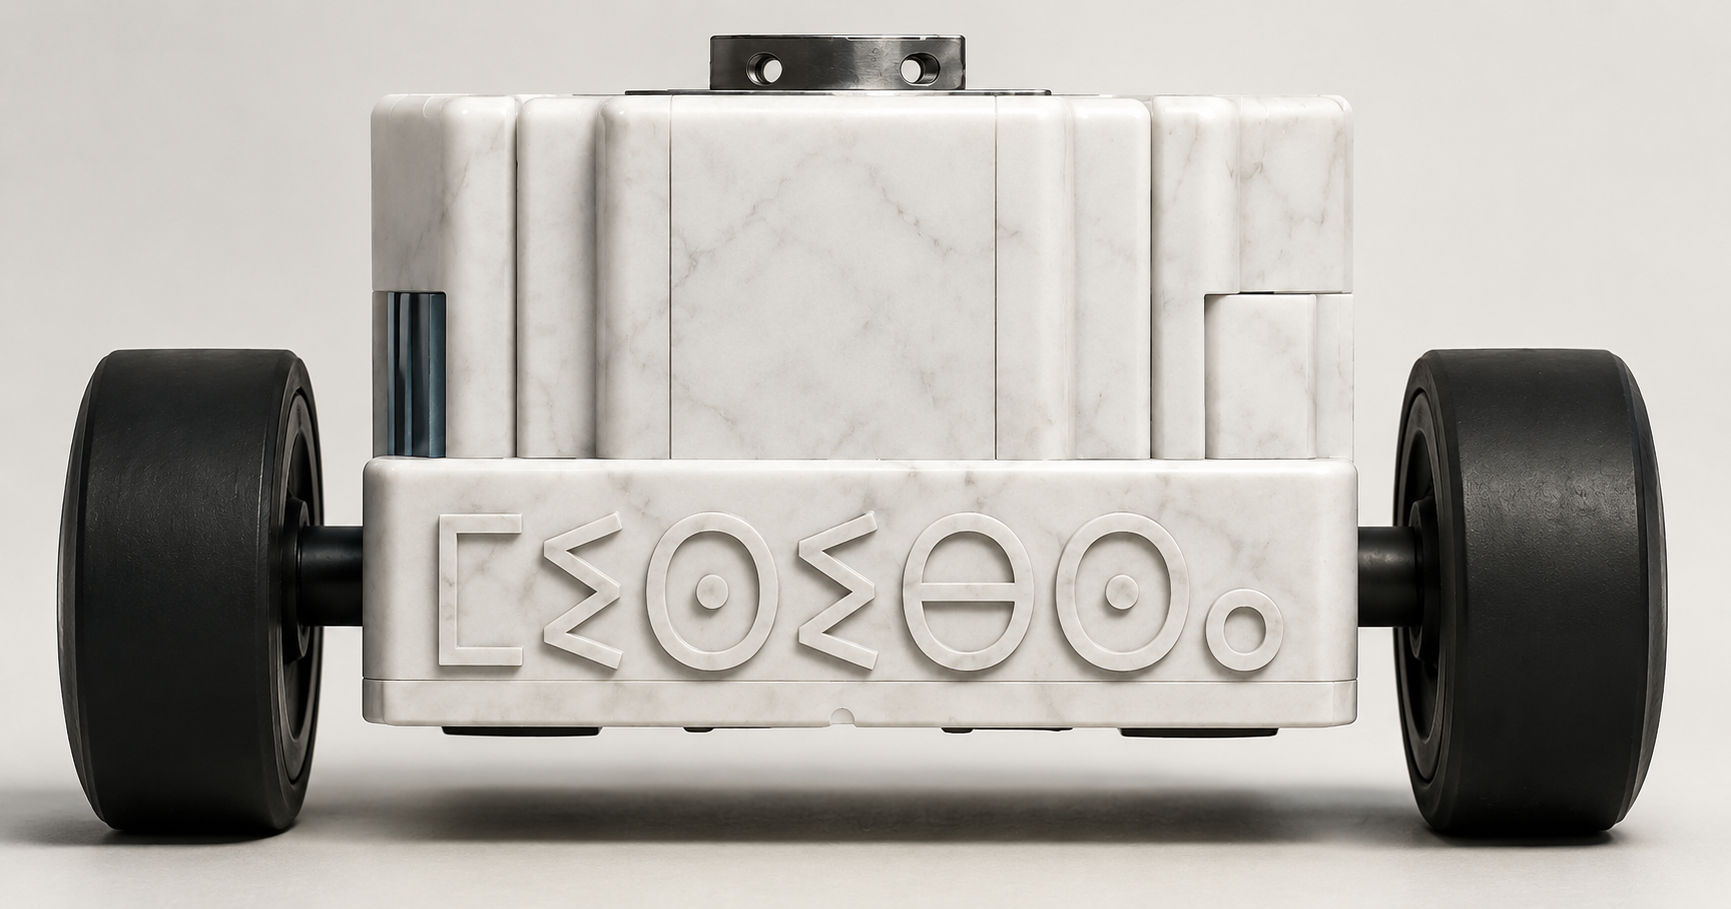
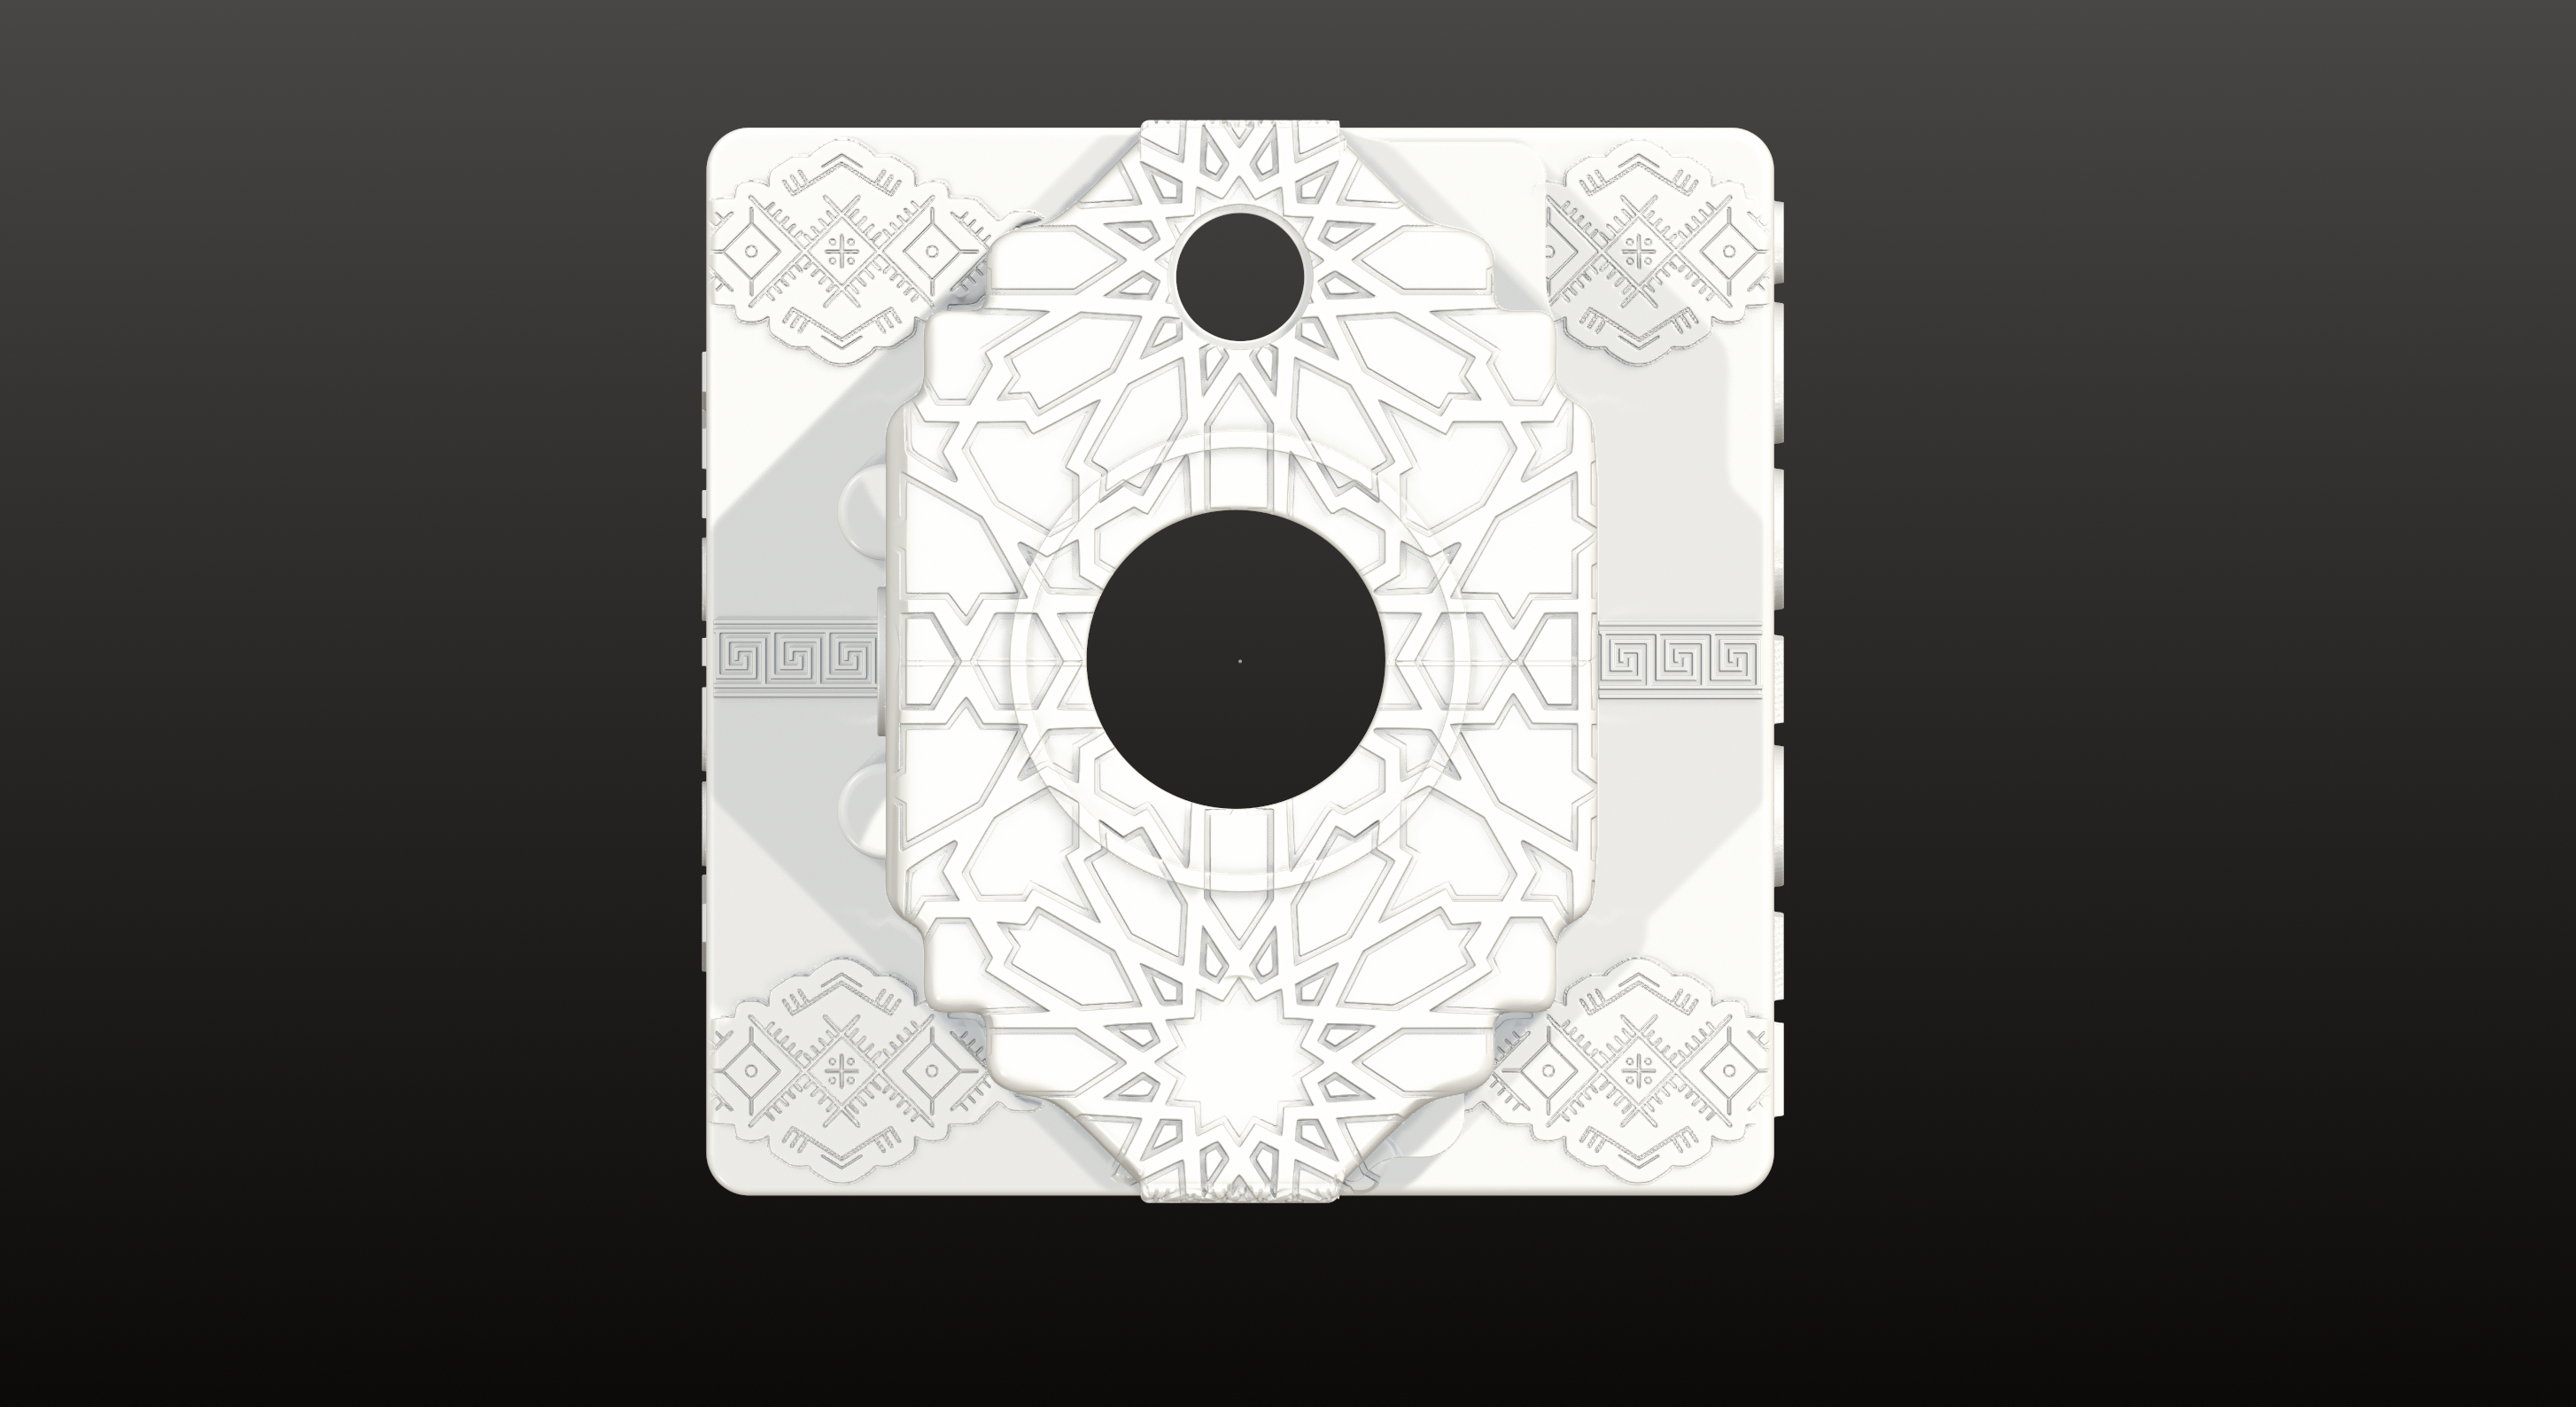
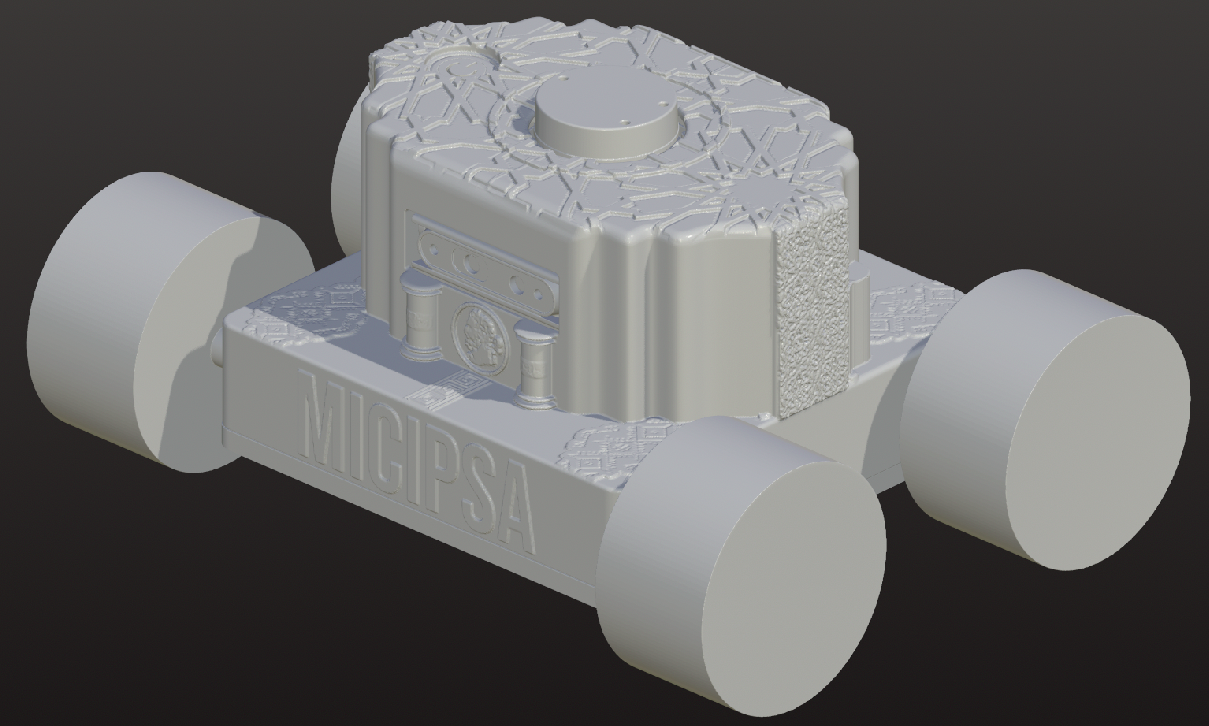
Developing on top of a poorly structured codebase and/or system only compounds complexity. Building an autonomous robot is already a challenging engineering problem and your infrastructure shouldn't make onboarding, debugging, extending and iteration even harder.
Rather than being a one-off research prototype, MICIPSA is built using real-world software engineering practices. It features a modular ROS 2 architecture, containerized deployment with Docker, and comprehensive documentation, providing a robust foundation for anyone looking to build, study, or extend a production-quality AMR stack.
Some History#
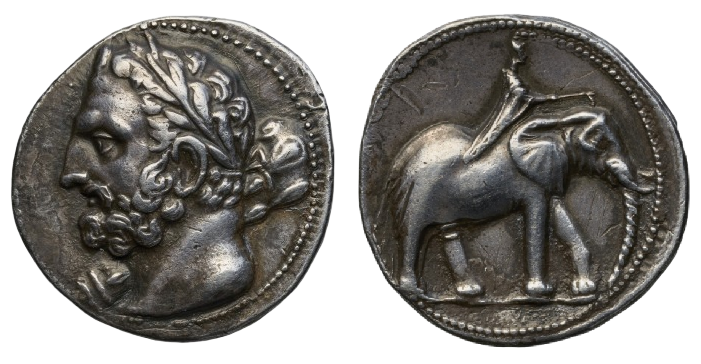
Micipsa (Numidian: Mikiwsan; Punic: 𐤌𐤊𐤅𐤎𐤍, MKWSN died c. 118 BC) was the eldest legitimate son of Masinissa, the King of Numidia, an Amazigh kingdom in North Africa current Algeria. Micipsa became the King of Numidia in 148 BC.
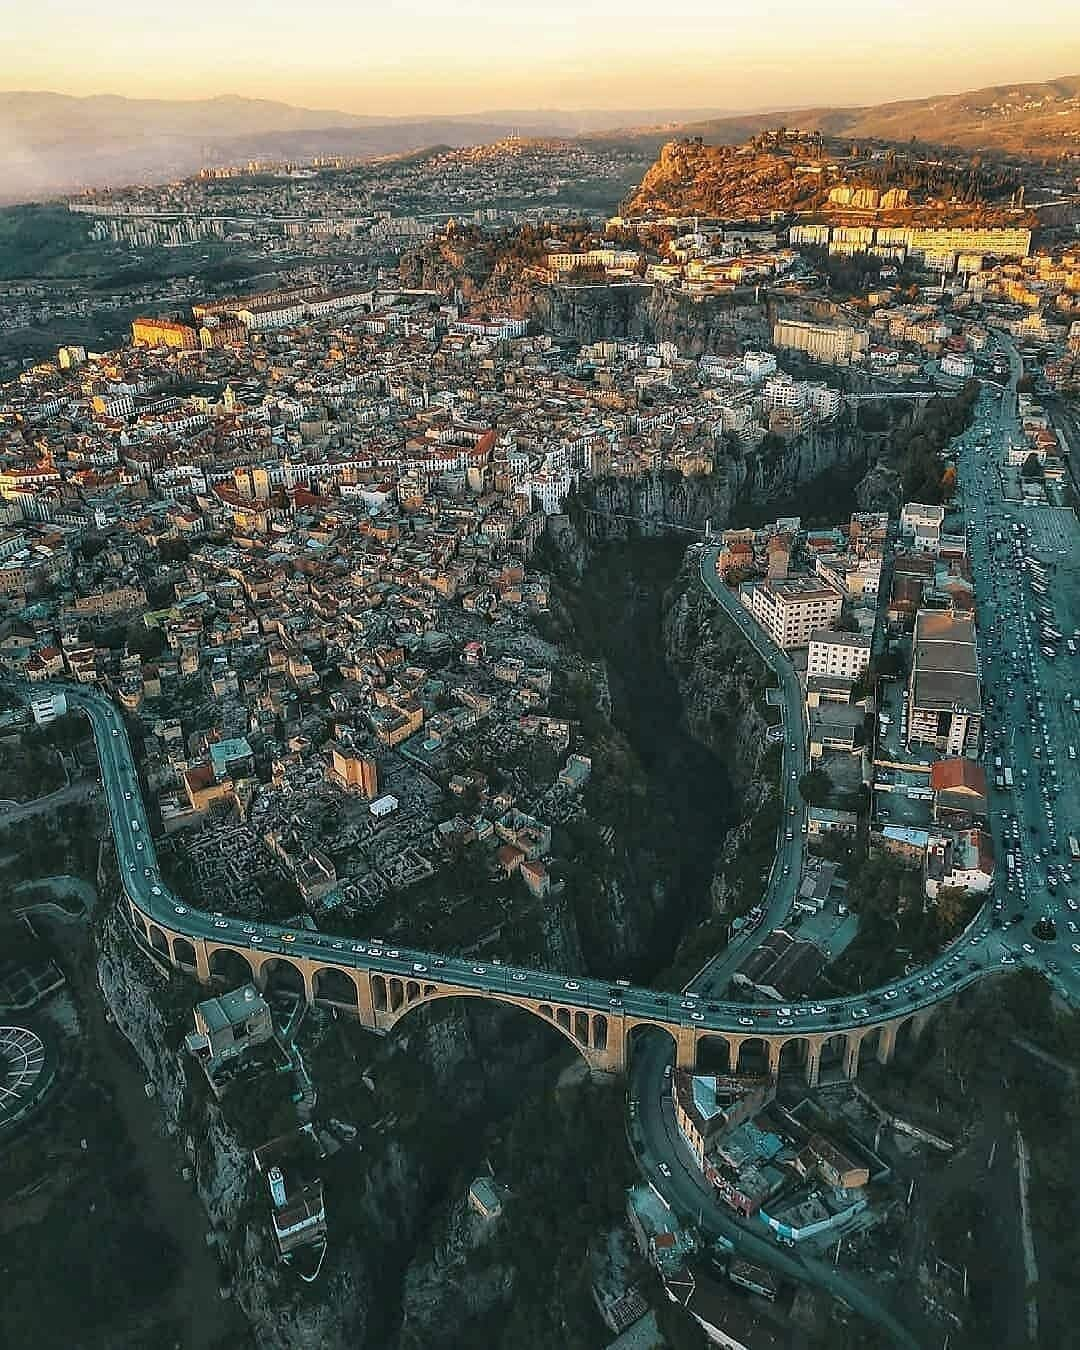
Ancient capital of the Kingdom of Numidia, originally known as Cirta, the city was later renamed Constantine in honor of the Roman Emperor Constantine the Great.
Documentation#
Important
Reading the documentation is strongly recommended.
New here? Start with About MICIPSA documentation in the Getting Started section for an overview of MICIPSA's key highlights.
Follow Understand MICIPSA Stack documentation in Getting Started section, it provides a recommended reading path through the documentation.
Following this roadmap will help you build a solid mental model of how the system fits together, making it much easier to navigate, understand, extend, and modify the stack without introducing regressions.
Micipsa Demos#
Deploy Demos#
Description Preview ▶️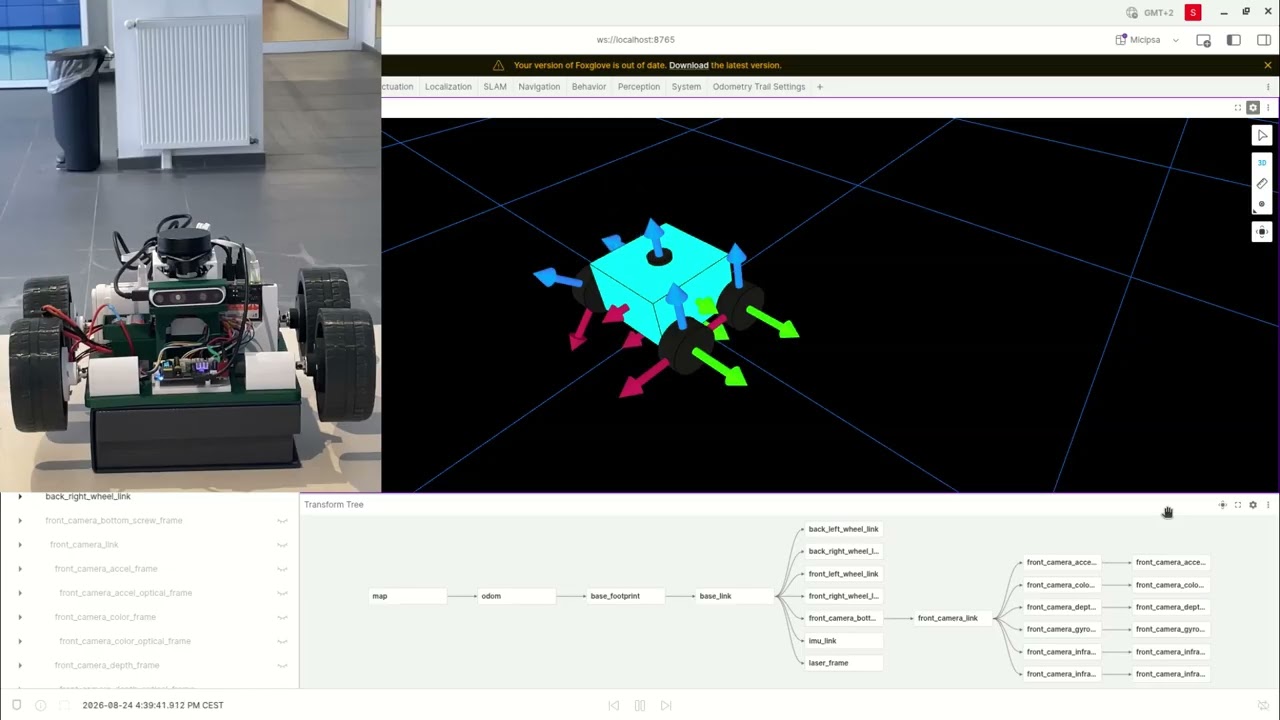
|
Actuation Preview ▶️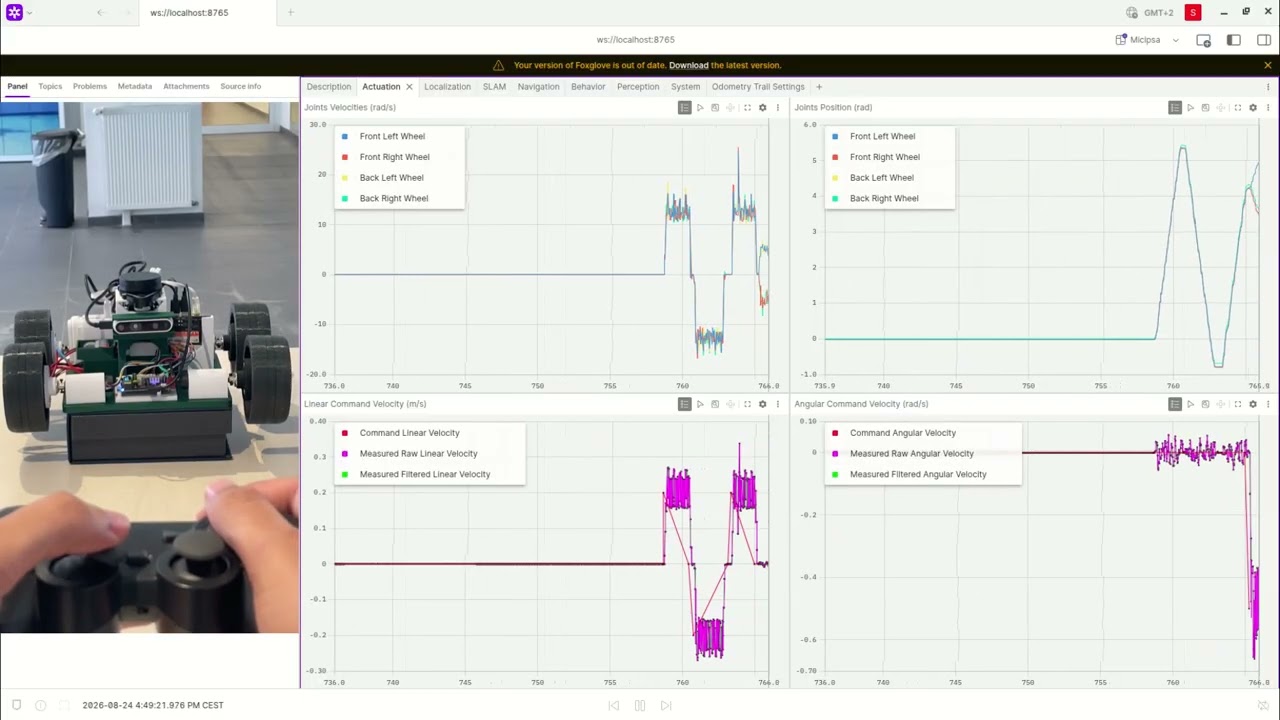
|
Localization Preview ▶️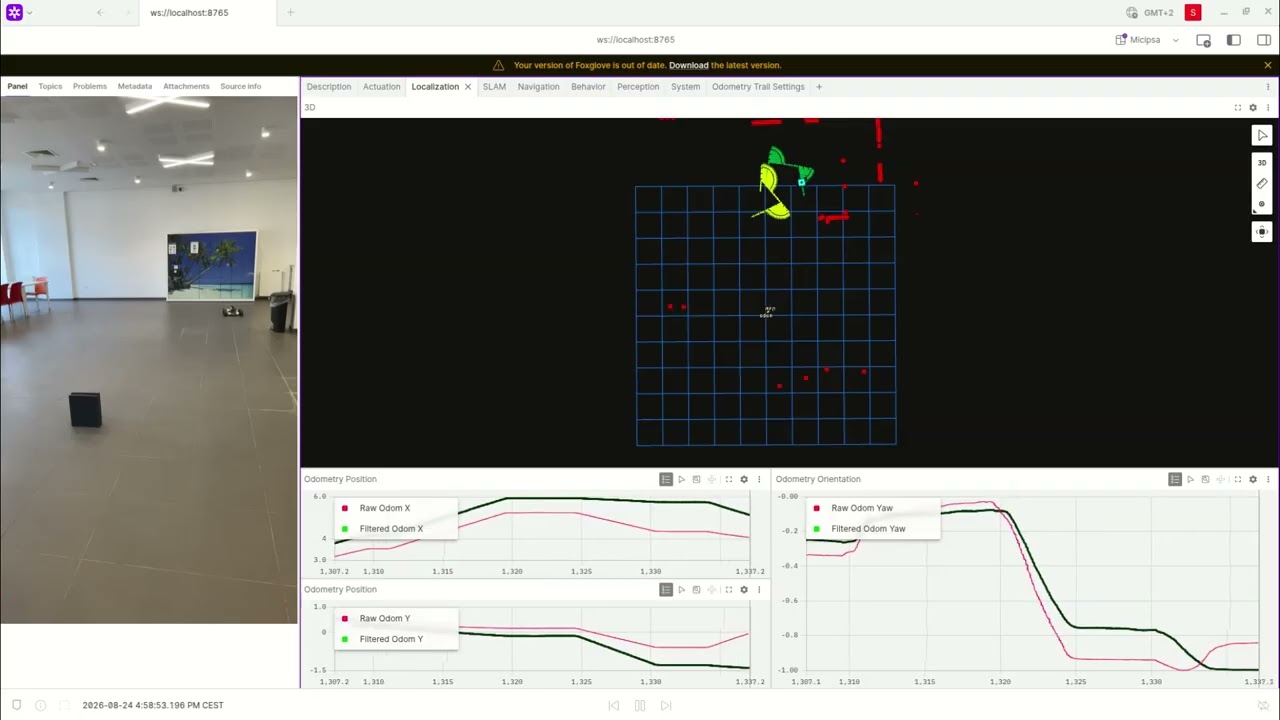
|
SLAM Preview ▶️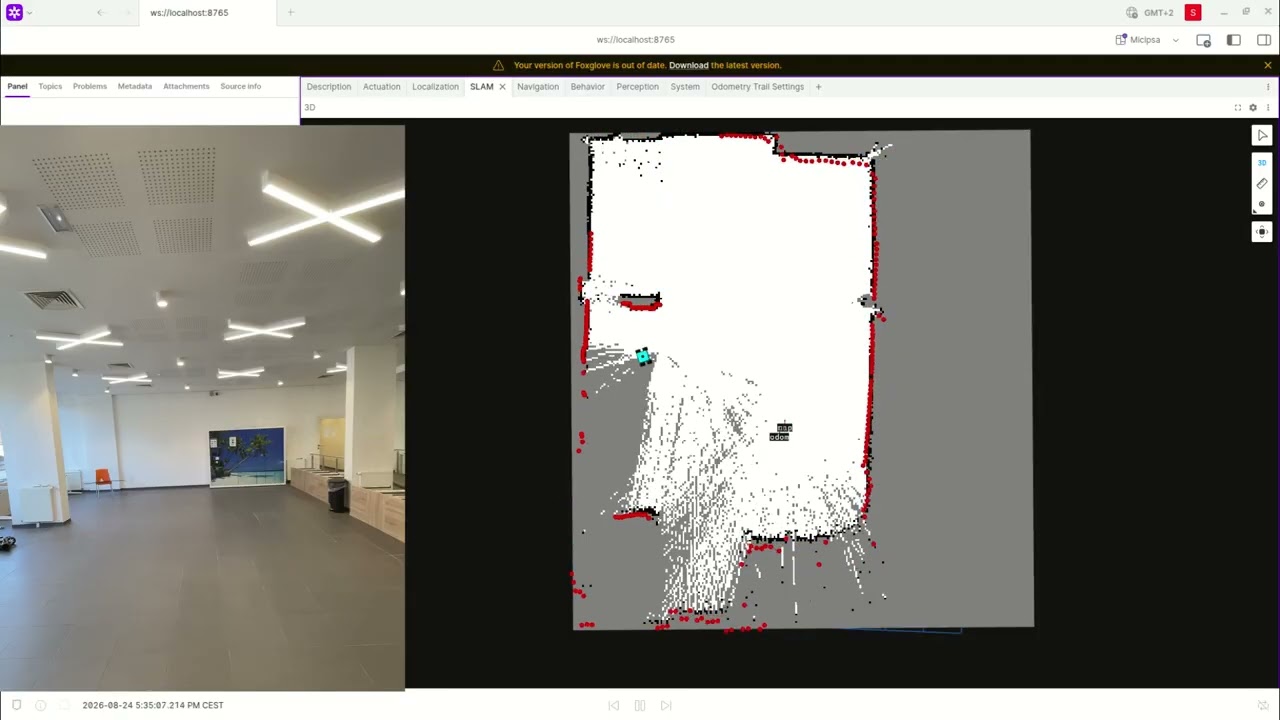
|
Navigation 1 Preview ▶️ 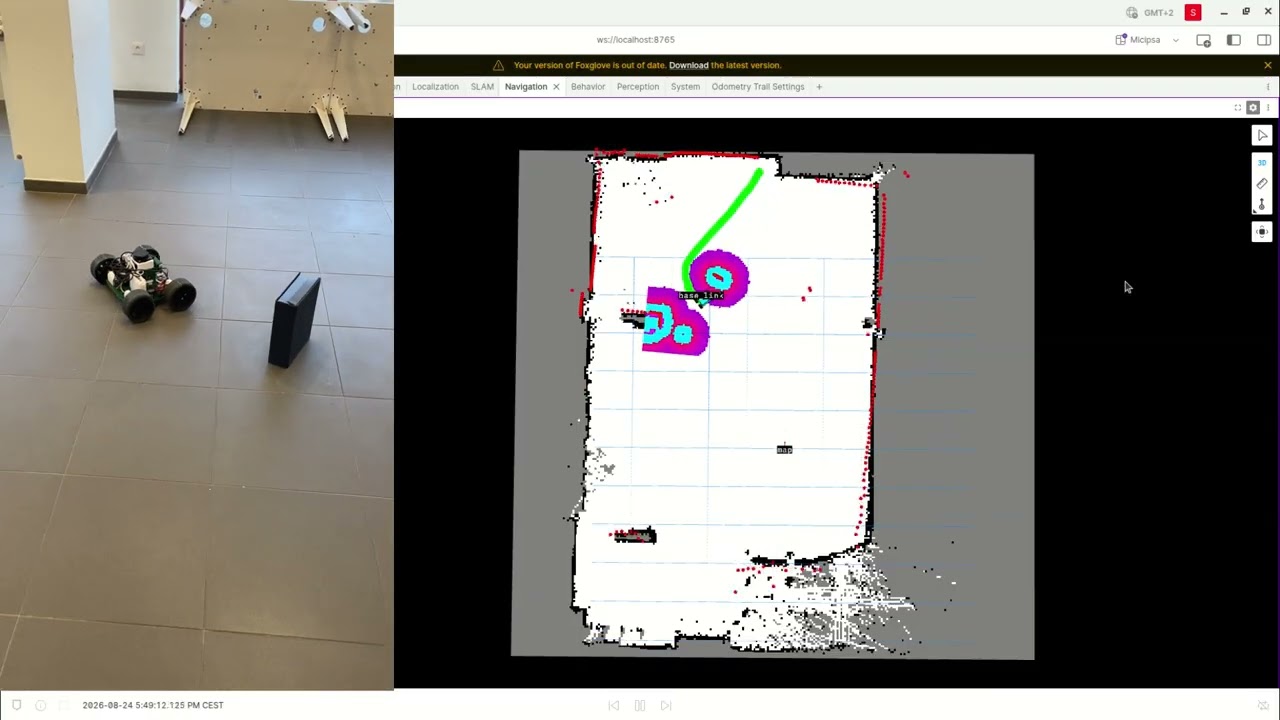
|
Navigation 2 Preview ▶️
|
Navigation 3 Preview ▶️ 
|
Navigation 4 Preview ▶️
|
Navigation 5 Preview ▶️ 
|
AprilTags Detection Preview ▶️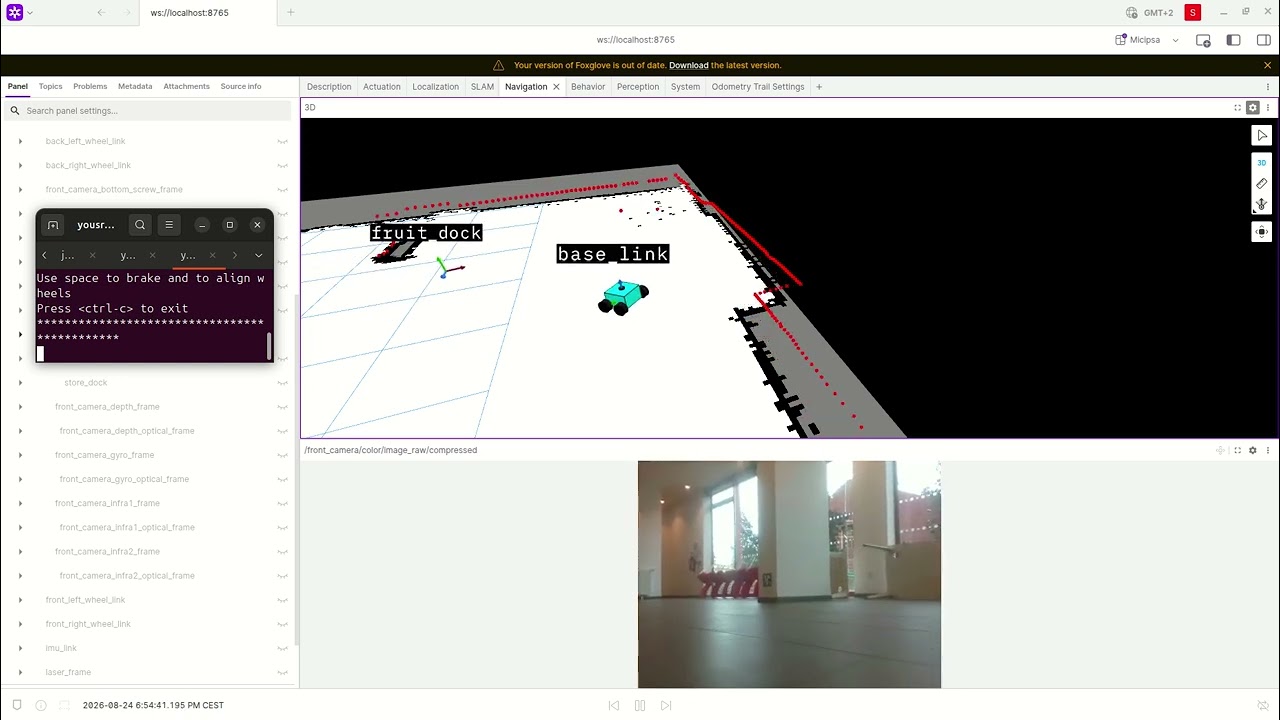
|
Simulation Demos#
Description Preview ▶️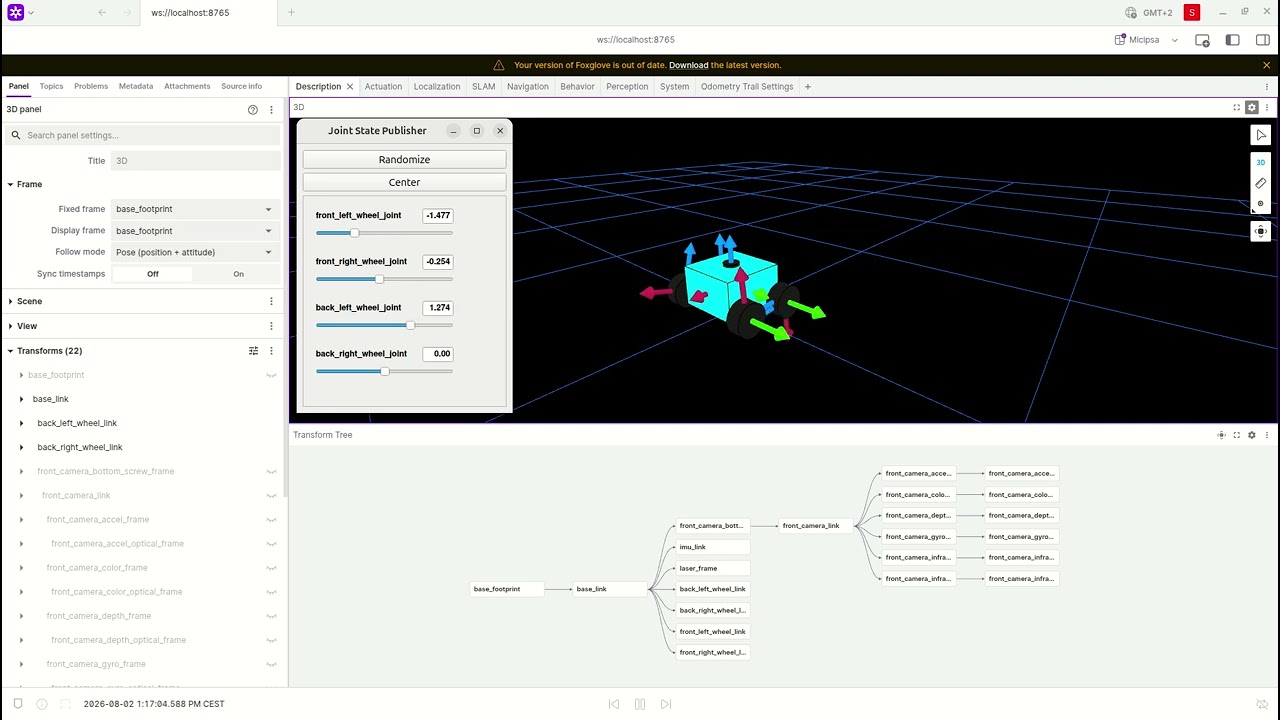
|
Actuation Preview ▶️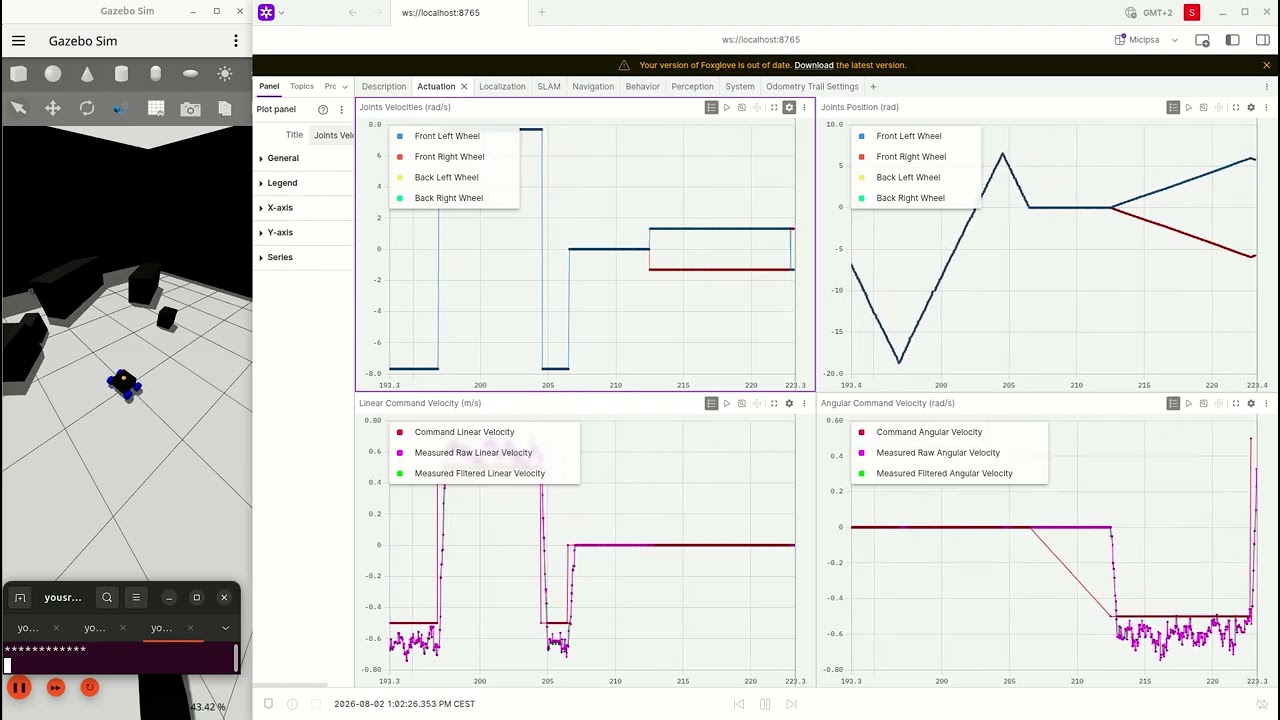
|
Localization Preview ▶️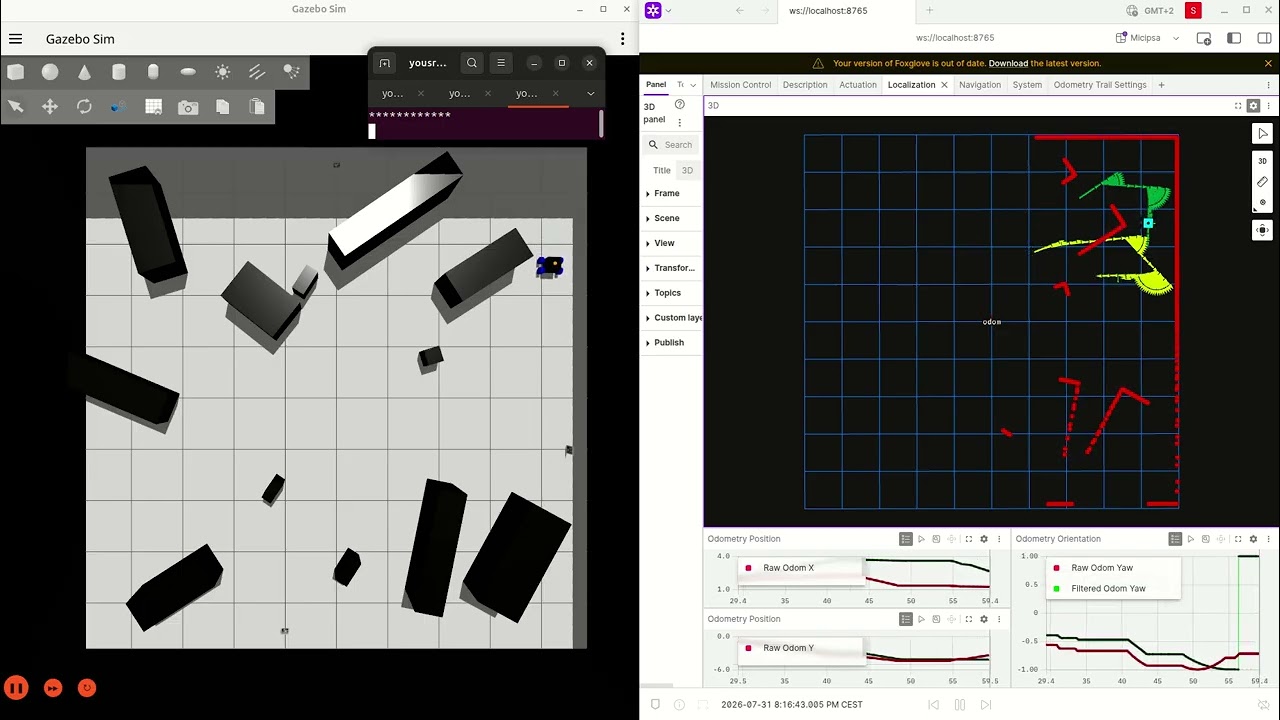
|
SLAM Preview ▶️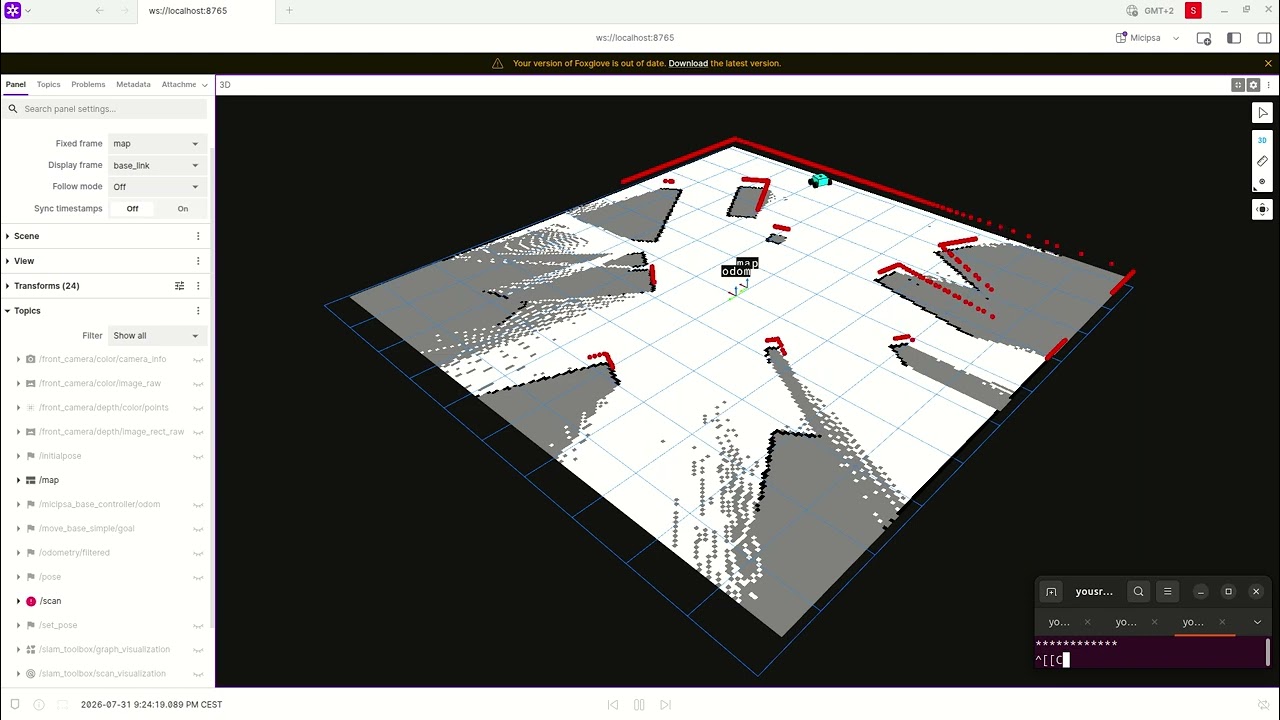
|
Navigation Preview ▶️ 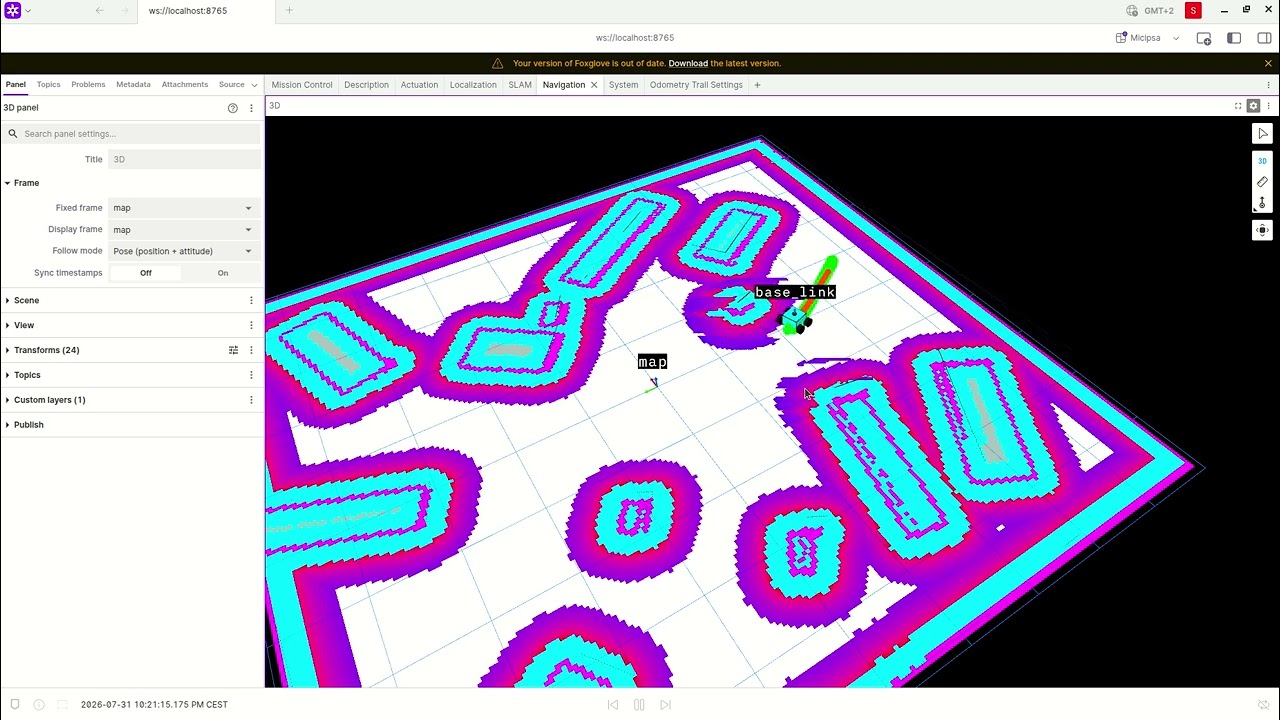
|
Behavior Preview ▶️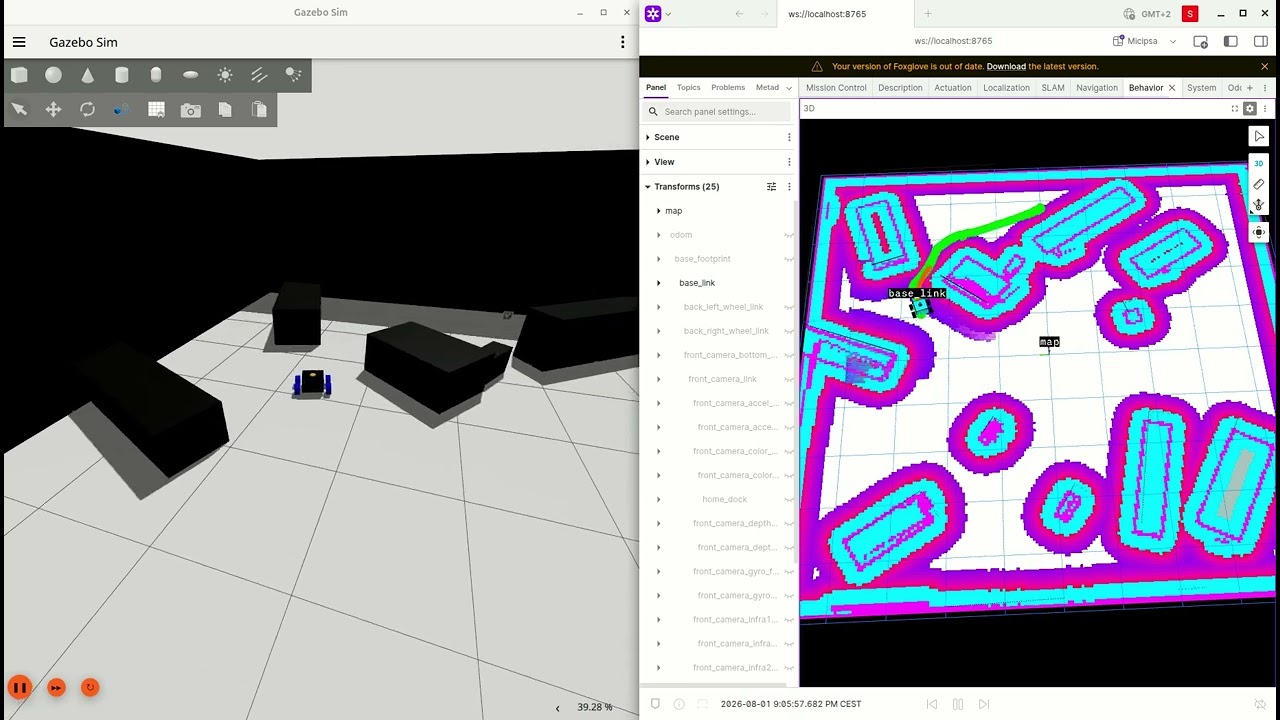
|
AprilTags Detection Preview ▶️ 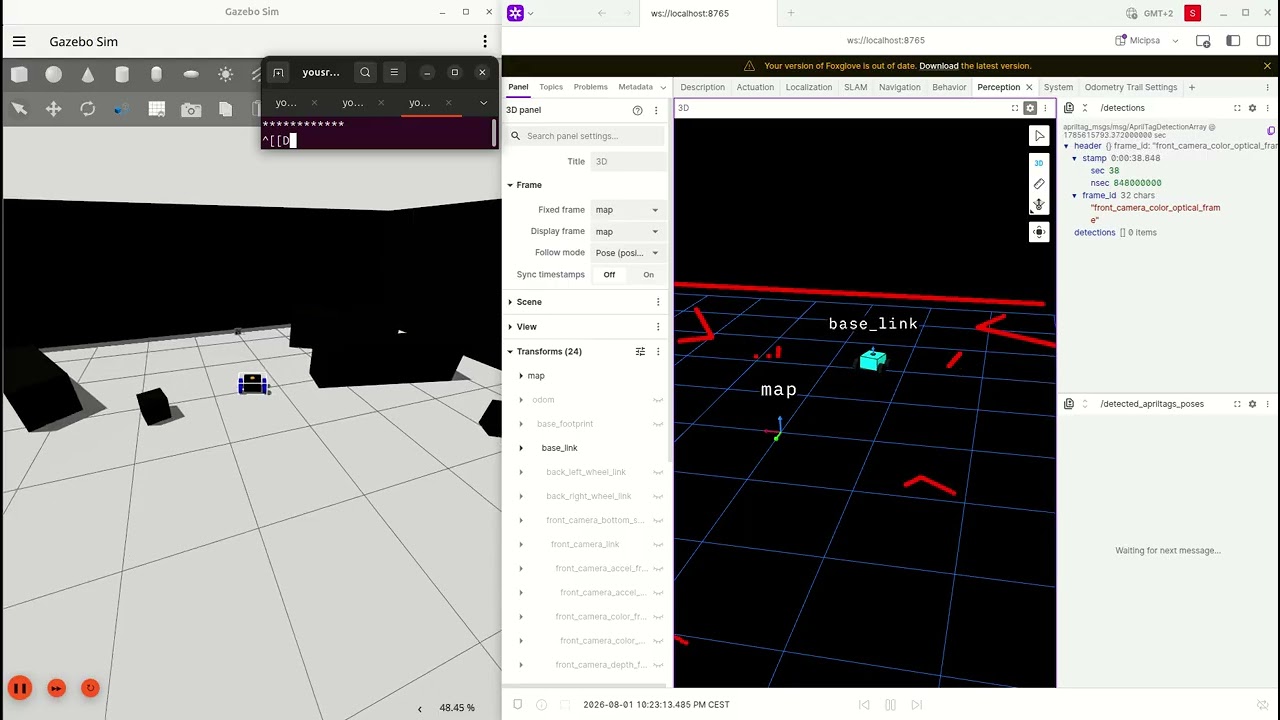
|
Pointcloud Processing Preview ▶️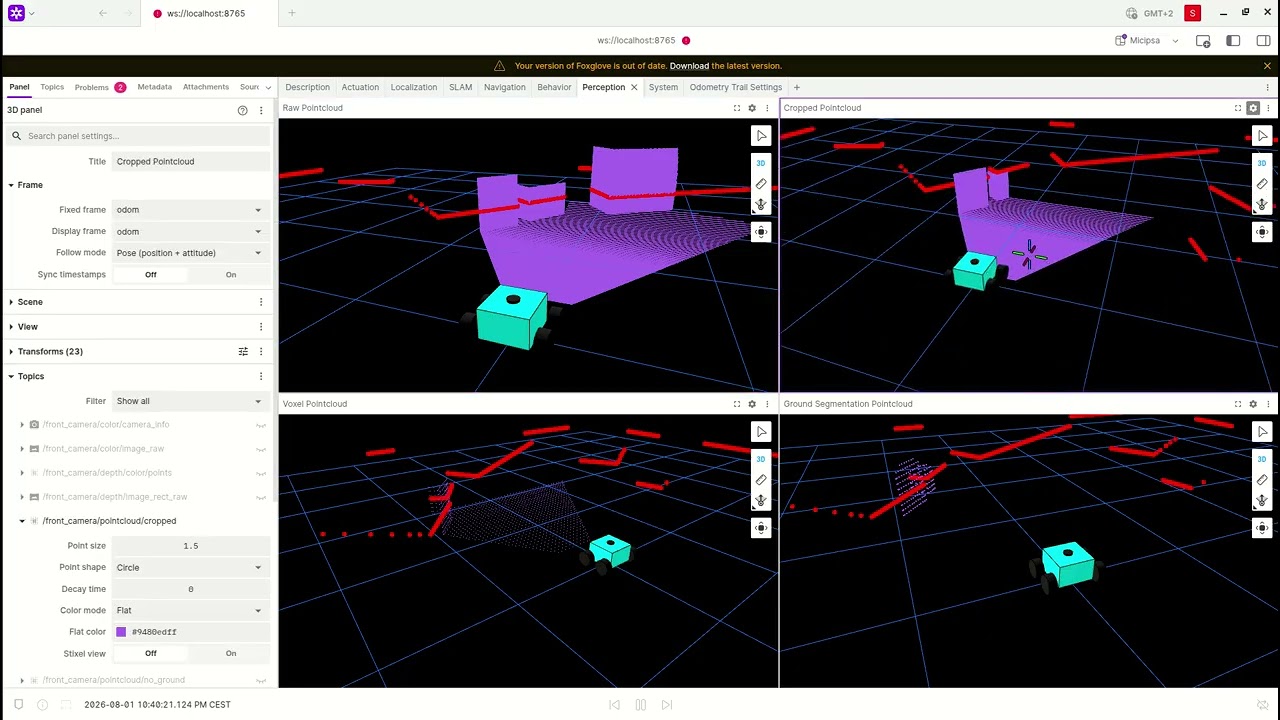
|